- Platform collects joint movement, muscle signals and ground reaction forces simultaneously
- Data to be used for humanoid robot motion control and rehabilitation technology
South Korean researchers have developed a technology to collect the AI training data needed to build humanoid robots capable of walking, running and grasping objects like humans.
The Korea Institute of Industrial Technology announced Wednesday that a research team led by Senior Researcher Ahn Beom-mo of its AI and robotics division has built a whole-body motion data collection platform called HHIP.
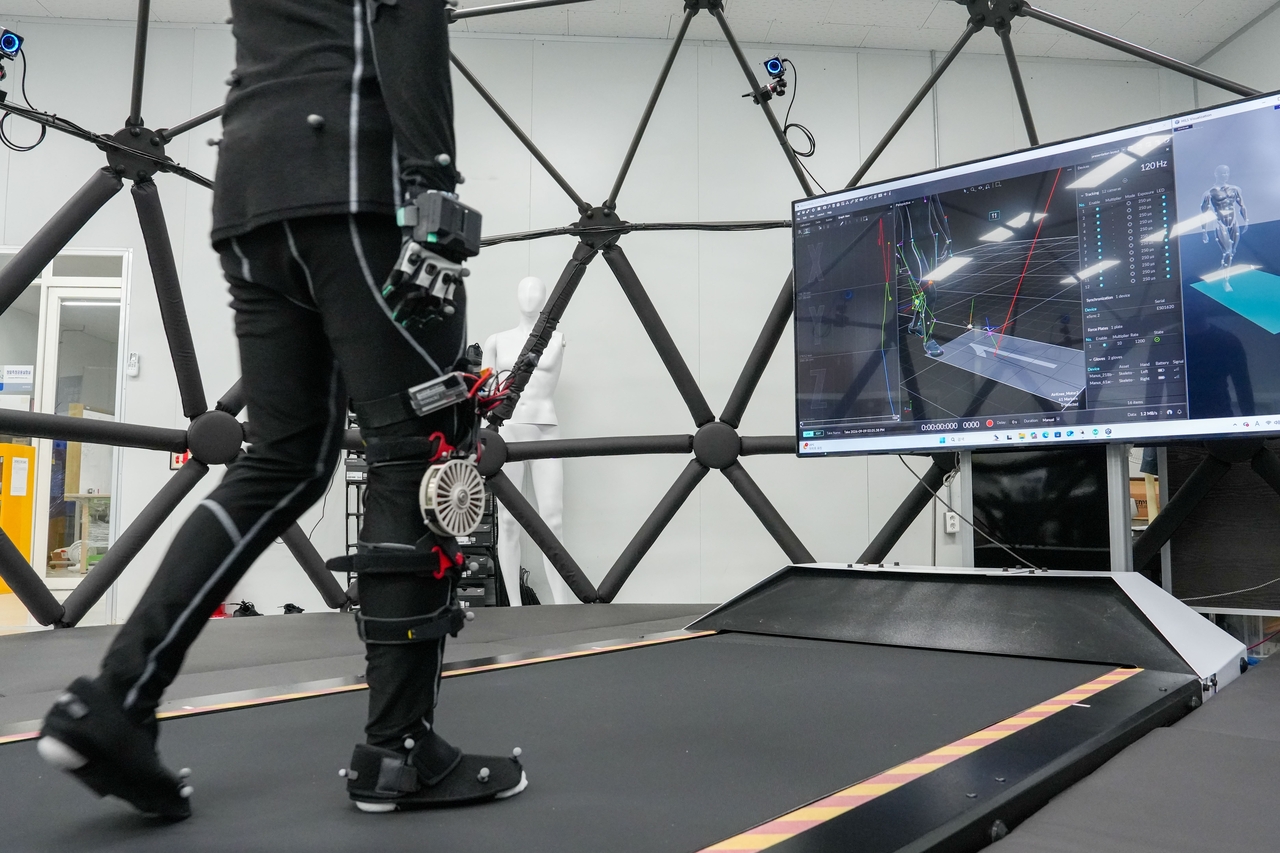
The platform simultaneously captures a range of biomechanical data, including joint movement, ground reaction forces from footsteps, finger motion and the electrical signals of muscles.
Conventional gait analysis has largely been conducted in hospital settings, where subjects walk briefly on a treadmill. That approach made it difficult to comprehensively analyze complex full-body movements beyond walking — such as running, jumping and object grasping.
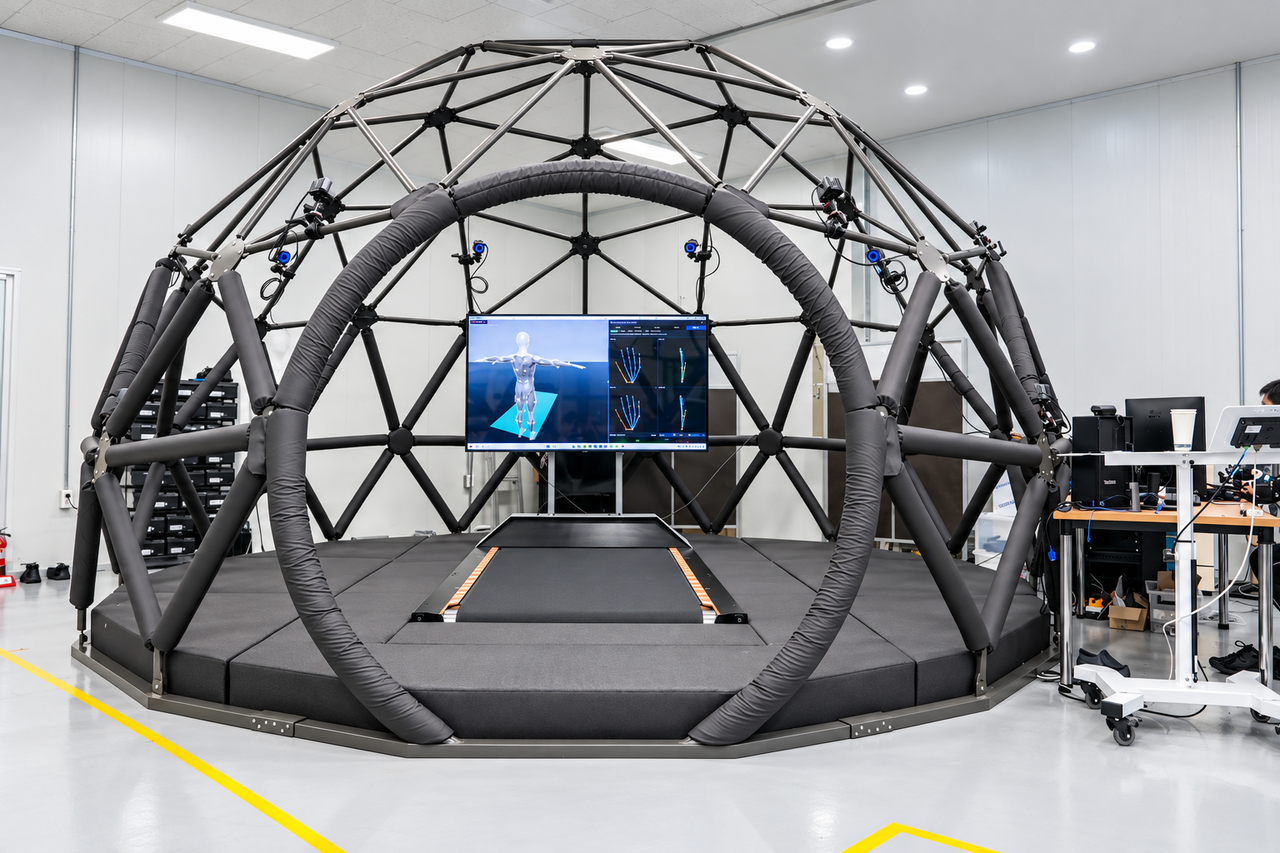
To address this, the research team installed a high-speed treadmill inside a dome-shaped structure and positioned optical motion-capture cameras around it.
When a subject attaches markers to their joints and moves on the treadmill, the cameras track joint positions and movement in real time. Force plates embedded in the floor measure the pressure exerted by each footstep, a glove-type sensor records finger movement, and electromyography sensors attached to the skin monitor muscle activation levels.
The treadmill operates at speeds of up to 45 kilometers per hour, enabling measurement of not only ordinary walking and running but also fast movement while wearing a wearable robot.
The key technical challenge is integrating data from multiple sensors onto a single unified time axis.
Even a slight mismatch between the moment a joint moves and the moment a foot touches the ground can compromise accurate motion analysis. The team developed its own software to align and store data from each sensor on a common time reference, then verified its accuracy.
The platform allows researchers to compare a subject's movement before and after putting on a wearable robot under identical conditions, enabling precise measurement of the device's actual assistive effect.
The team has already used the platform to validate the performance of AirKnee, the world's lightest knee-assist wearable robot — confirming whether the knee joint moves at the intended angle when worn and whether physical strain is reduced during walking or lifting.
More recently, the platform has been used to collect human task-motion data for developing AI control models for humanoid robots. The goal is to accumulate joint-movement data recorded while people perform real tasks and use it as training data so robots can move more naturally and precisely.
"The core of the platform lies in how accurately it can capture human movement as data," Ahn said. "We plan to build up a diverse library of task-motion data and apply it not only to humanoid robots but also to wearable robots and rehabilitation."
nbgkoo@heraldcorp.com