- KAIST, Caltech and Singapore's NTU jointly develop soft robot with vision and touch sensing
- Robot navigates obstacles and transports objects, raising hopes for remote work in tight, hazardous spaces
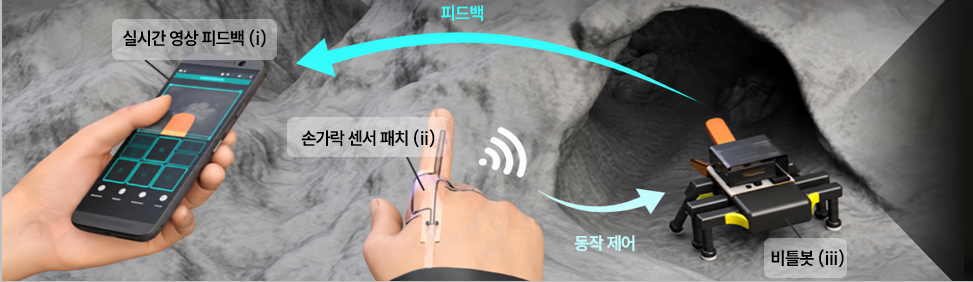
A "beetle robot" that walks, changes direction and picks up objects in response to a user's finger movements has been developed by researchers in South Korea.
KAIST announced Tuesday that a research team led by Professor Kim Sang-uk of the Department of Materials Science and Engineering had jointly developed an artificial muscle-based soft robot called BeetleBot with teams from the California Institute of Technology (Caltech) and Nanyang Technological University (NTU) in Singapore.
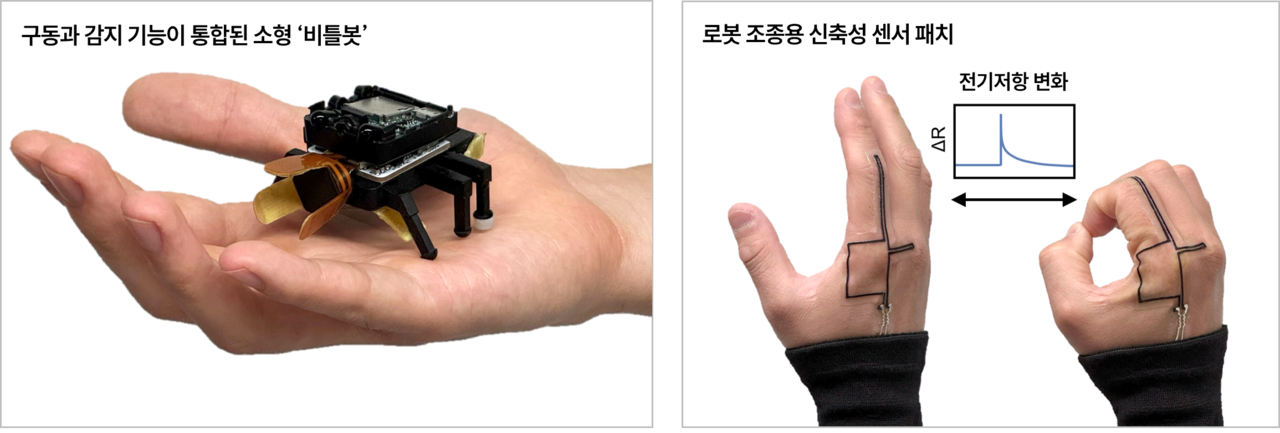
BeetleBot is a small robot modeled on the legs and mandible structure of a beetle. While conventional soft robots have handled locomotion and sensing as separate functions, BeetleBot integrates walking via artificial muscles, object grasping, visual and tactile sensing, and user control into a single system.
At the heart of the robot is an artificial muscle that contracts like real biological muscle. The research team fabricated the artificial muscles by 3D-printing liquid crystal elastomer (LCE), a polymer material that contracts when heated, then coupled it with an electrically driven heating element to move the robot's legs.
By controlling the sequence in which the artificial muscles in each leg are activated, the robot can walk forward or turn left and right.
The gripper — modeled on the mandibles beetles use to seize prey — also incorporates artificial muscles and a pressure sensor. When the artificial muscle contracts, the gripper closes around an object, while the pressure sensor detects whether contact has been made.
Particularly notable is that the robot can be operated using only the fingers.
The team developed a stretchable sensor patch that registers changes in electrical resistance as the fingers bend and extend. Carbon nanotubes (CNTs) embedded in the patch generate electrical signals in response to finger movements, which are then translated into four commands: move forward, turn left, turn right, and grasp an object.
Those commands are transmitted to the robot via Bluetooth. The user can monitor the surroundings through a small camera mounted on the robot and determine whether an object has been properly grasped through the pressure sensor on the gripper.
The setup constitutes a "bidirectional feedback" system in which information sensed by the robot is relayed back to the user, who then decides the next action based on that input.
In practice, the team successfully demonstrated BeetleBot navigating around obstacles to reach a target object, gripping it with the mandible-style gripper, and transporting it to another location.
The technology could find use in remote operations such as inspecting narrow gaps in industrial equipment or spaces too confined for humans to enter directly, as well as retrieving small components or samples.
However, deploying the robot in actual industrial settings will require improvements in the artificial muscles' actuation speed, energy efficiency and durability, as well as in power supply and communication stability.
The team plans to develop artificial muscles capable of operating quickly at low temperatures and to refine the technology for incorporating visual and tactile data into the robot's motion control.
"This research is a meaningful step toward expanding the potential of soft robotics by linking artificial muscle movement, sensory feedback and user control into a single system," Kim said. "We expect it to contribute to the advancement of soft robots that can operate in spaces difficult for humans to access."
The findings were published in the international journal Science Advances on Aug. 19.
nbgkoo@heraldcorp.com