- KAIST Professor Hwangbo Jemin's team's 'RAIBO2' finishes 42.195 km on a single charge
- Robot can travel up to 65 km per charge; findings published in Nature
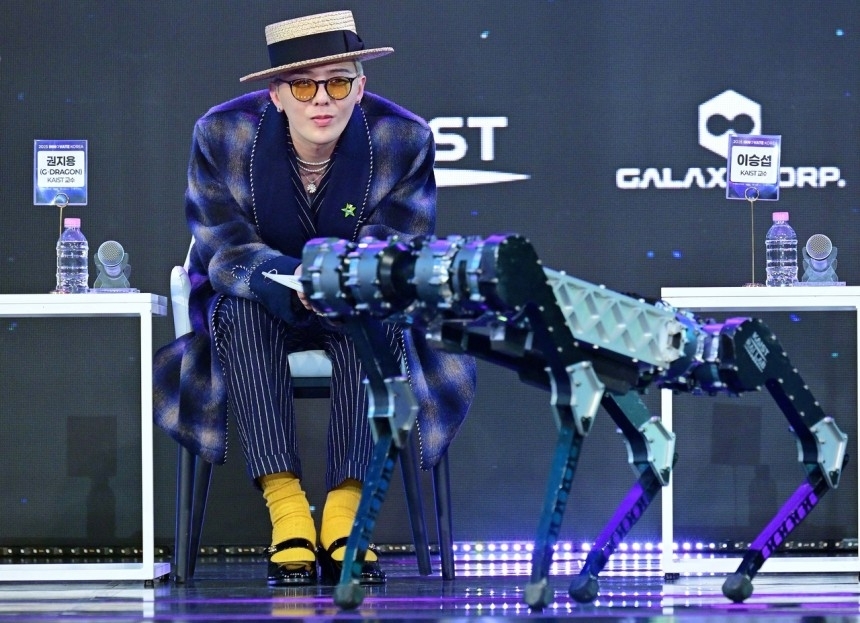
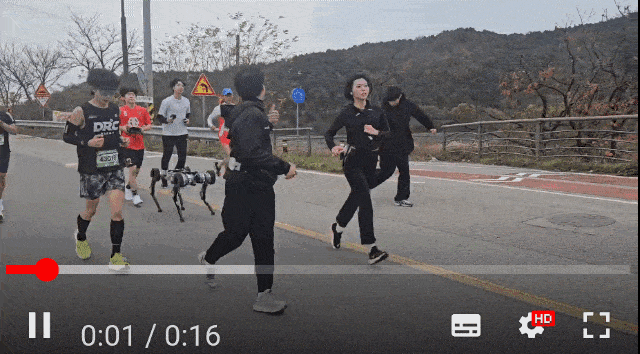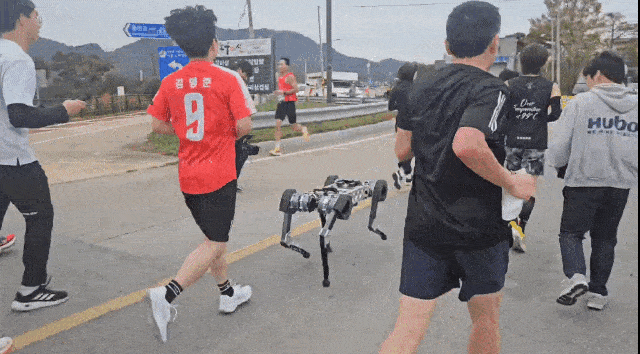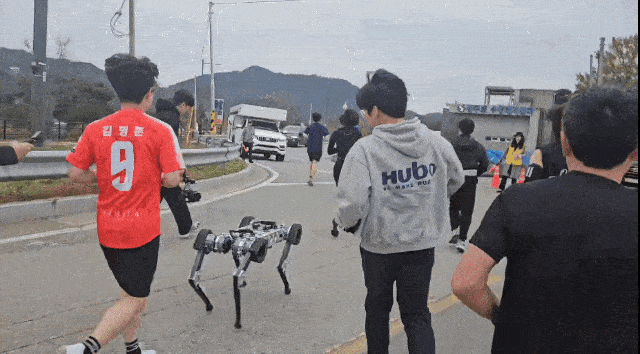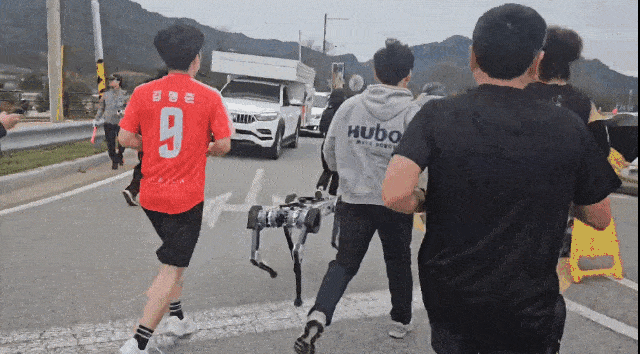
A South Korean quadruped robot has completed a full 42.195-kilometer marathon without a single battery swap — covering more than three times the distance of its closest American and Chinese rivals on the same charge.
KAIST announced Thursday that the long-distance running technology developed by mechanical engineering Professor Hwangbo Jemin's research team, along with the results of the robot's actual marathon run, had been published in the journal Nature. It marks the first time a robotics study conducted in South Korea has appeared in the main issue of Nature.
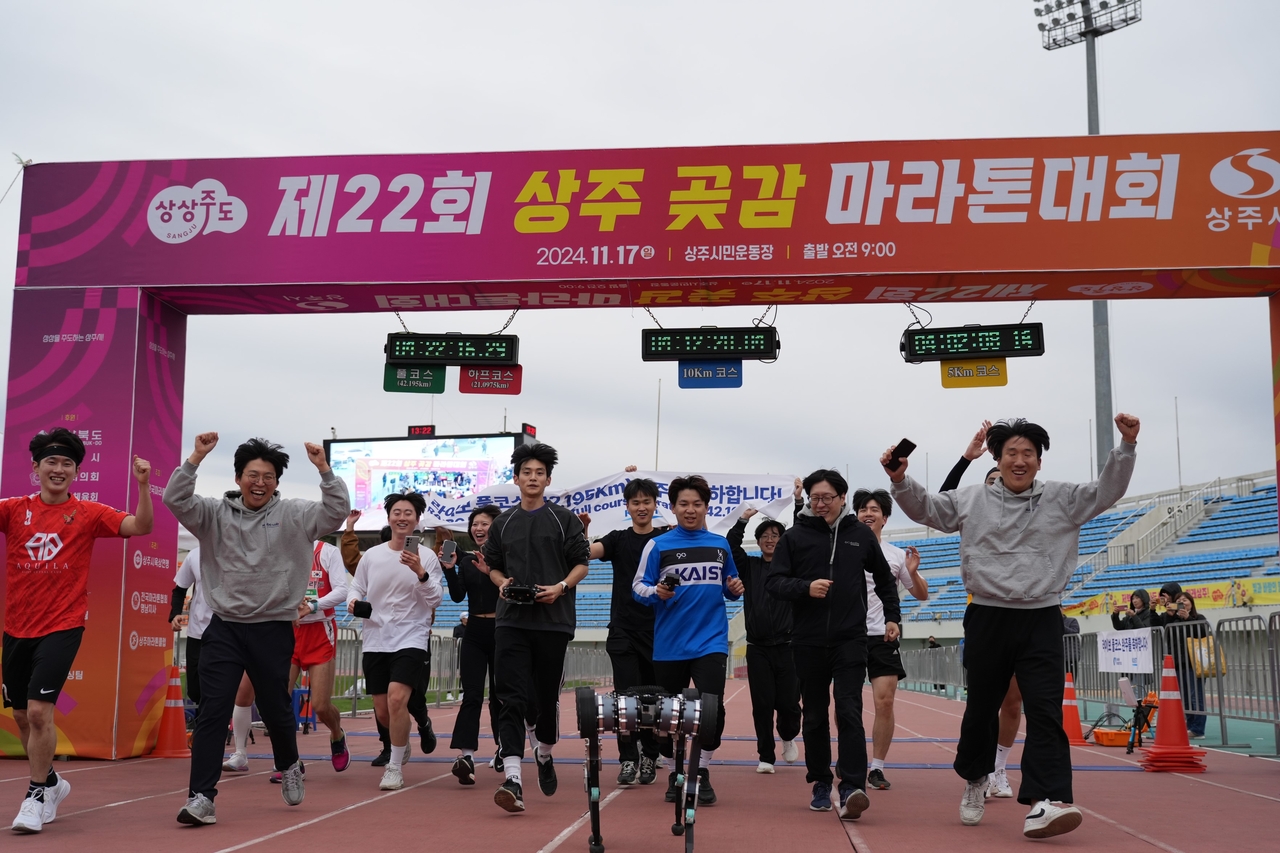
The robot, named RAIBO2, completed the full 42.195-kilometer course at the Sangju Gotgam Marathon in November 2024 in 4 hours, 19 minutes and 52 seconds without recharging or replacing its battery. It was the first time a quadruped robot had completed a full marathon course in an actual race. The robot averaged about 9.5 kilometers per hour over a course that included slippery sections covered in fallen leaves and slopes of up to 18.4 degrees.
Even more striking, the battery still had about 34 percent charge remaining at the finish line. When the research team applied the marathon run data to the robot's full battery capacity, they calculated that RAIBO2 could travel up to approximately 65 kilometers on a single charge.
On an equivalent battery capacity, that range is more than three times greater than that of leading global competitors, including Ghost Robotics' Vision60 from the United States and Unitree's B2 from China.
The secret was not simply a bigger battery. The research team focused on minimizing energy loss generated by the robot's movement itself.
Unlike wheeled robots, quadruped robots require their joint motors to continuously support the body even when standing still. When the legs move, friction builds up in the joints and reducers; each time a foot strikes the ground, energy is lost to impact and slipping. Heat generated by the motors and electrical circuits adds to the losses as well.
The team treated this not as a problem with any single battery or motor, but as a system-wide challenge. They integrated the mechanical structure, electrical systems, actuators and AI-based gait control into a unified system to reduce energy loss across the board.
RAIBO2 features lightweight legs designed to reduce joint friction and inertia, along with high-efficiency actuators for better force transmission. Reinforcement learning-based gait control suppresses foot slipping and slows the foot just before ground contact, cutting the energy lost on impact.
The team's next goal is to translate the world-record performance into a commercially viable industrial robot.
RAIBO2 is a research prototype designed and built by the team itself. Deploying it in industrial settings will require consistent performance across multiple production units, as well as field reliability standards — including waterproofing, dustproofing, resistance to shock and vibration, and operation across a wide temperature range.
Lion Robotics, a faculty startup founded by Hwangbo at KAIST, is handling commercialization. The company is developing its own mechanical structures, electronics, software, AI and even the motor drivers that precisely control the robot's motors as it works to secure the mass-production technology needed for industrial quadruped robots.
"This research goes beyond showing how far a quadruped robot can run — it uses real marathon data to demonstrate how an entire robot must be designed to achieve both high locomotion performance and energy efficiency at the same time," Hwangbo said. "We will take the world-class performance we achieved in the lab and turn it into a product that anyone can use reliably in the field."
nbgkoo@heraldcorp.com